Adithya Rajendran

M.S. Engineering student at SJSU

I study detection errors and how another camera view can help verify a remembered object.

Open to Summer 2027 internships · Full-time opportunities in 2028

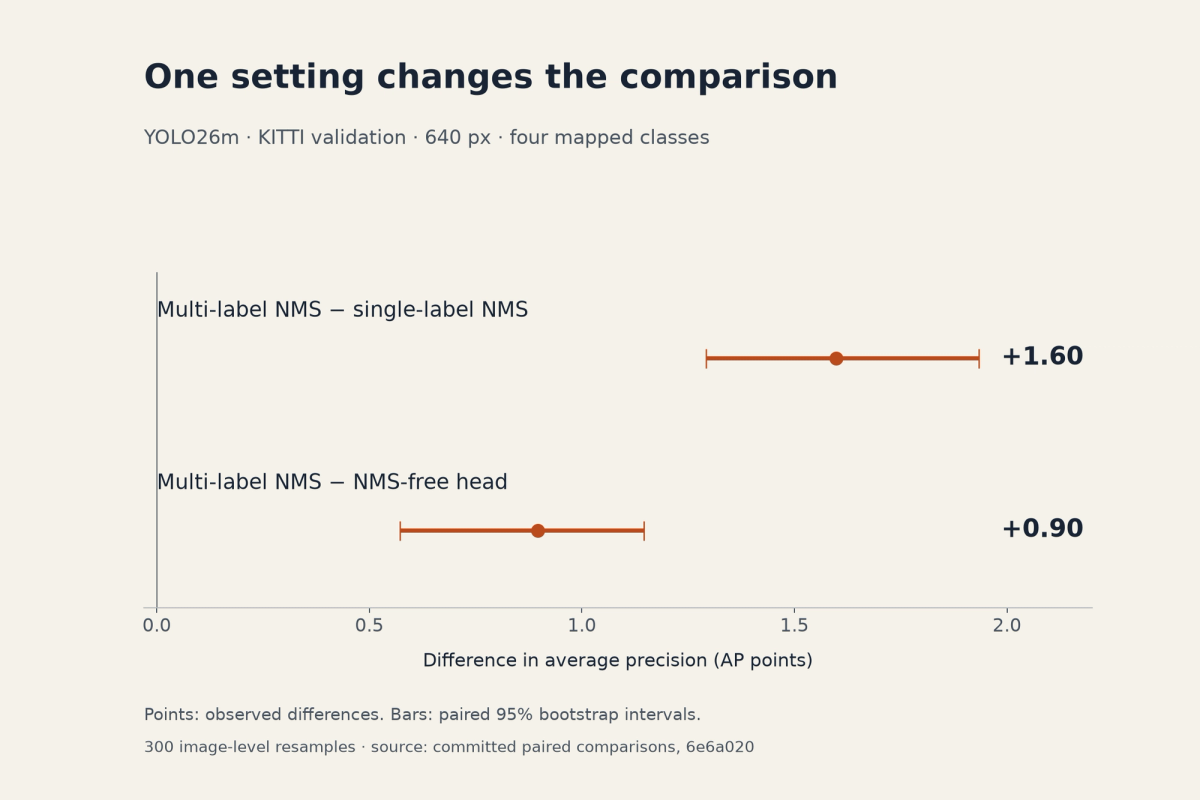
On KITTI at 640 px, multi-label NMS raised AP by 1.60 points and reversed a head-to-head comparison.

Complete2026

Evaluating detectors on driving scenes 

Changing one post-processing setting raised YOLO26m KITTI AP from 26.20 to 27.80 and reversed its comparison with the NMS-free head. A CMPE 249 study of evaluation settings, domain shift, and inference latency.

  • Python
  • PyTorch
  • Ultralytics
  • pycocotools
Multi-label NMS improves AP by 1.60 points over single-label NMS and 0.90 over the NMS-free head, with paired 95% bootstrap intervals.
YOLO26m, KITTI validation, 640 px, four classes. Paired 95% bootstrap intervals, 300 image-level resamples.
  • Active2026

    When should a robot look again?

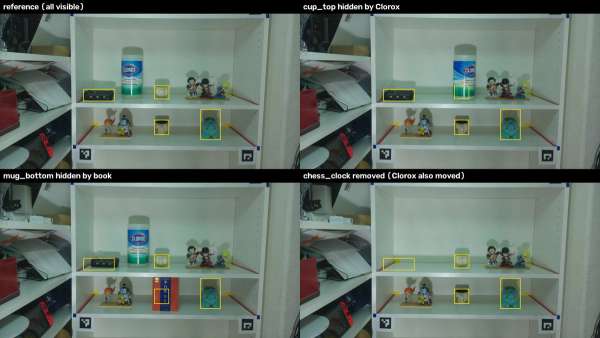
    Four shelf views showing a reference, two occlusions, and a removed chess clock.
    First development pilot: one viewpoint and lighting condition. The evidence code was adjusted on these images.

    A first camera pilot for checking whether a remembered object has been removed or is hidden. Capture and verification code is built; comparison of view-selection policies is the next experiment.

  • Active2026

    Local coding agents: task success and resource use

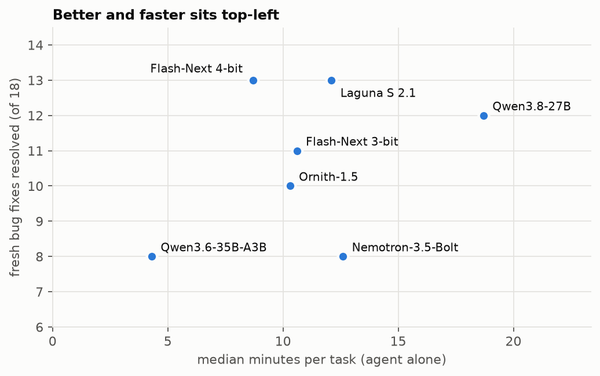
    Scatter plot of resolved coding tasks out of eighteen against median task time.
    October 25 snapshot: small task samples and mostly one primary attempt per configuration.

    Seven model/server configurations on one GX10, measured by completed bug fixes, task time, GPU energy, and memory use. The October 25 snapshot includes 18 fresh-PR tasks and 11 SWE-bench Pro tasks.

  1. 17 min read

    Keeping a DGX Spark reachable under memory pressure

    Why model loads made my GB10 host unresponsive, how a memory guard intervenes, and what the tests establish about its limits.

  2. 6 min read

    A Homelab Built to Be Rebuilt

    How three Raspberry Pis, an old Dell laptop, and three mini PCs bootstrap my OpenStack lab—and why I keep the NAS and GPU systems outside that chain.

  3. 6 min read

    Running GUI apps in LXD containers

    The LXD profile I use to run GUI tools on my Linux desktop, with shared display sockets, GPU access, and the limits of that isolation.

Research and collaboration

Working on robotic perception, object memory, or reliable ML systems? I’d welcome a conversation about research, collaboration, or an opportunity to contribute.

Current focus